Robot joint actuator parts
Integrated joints, frameless motors, strain-wave, planetary and cycloidal reducers, crossed roller bearings, encoders, drivers and brakes, from 159 makers in 19 countries. Every part shows its specs, who makes it, its price with a source, and where it is made.
Have numbers? Start there
Pick a starting point, then change any number. Every part is checked against what you enter.
Buy a joint integrated
Motor, reducer, driver and encoder already assembled and tuned. 81 to compare.
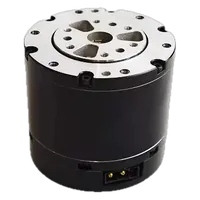
Or build your own
Every part one joint needs, in the order you design it. The full list with picks is on Build a robot joint actuator.
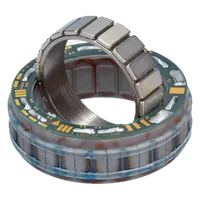
Motor
Frameless kits build into your own housing; outrunners suit low-ratio quasi-direct-drive joints.
Reducer
Strain-wave for zero backlash in a short package, planetary for backdrivable QDD joints, cycloidal for shock and high load.
Output bearing
One crossed roller bearing carries the radial, axial and tilting load at the joint output.
Encoders
A motor-side encoder for commutation and, for accurate joints, a second absolute encoder on the output.
Driver
A compact FOC servo driver that mounts on the joint and talks CAN or EtherCAT to your controller.
Holding brake (optional)
Holds the joint when power drops, so an arm or leg does not fall.
Smart servos and linear actuators
Serial bus servos for small joints and grippers; linear actuators for push and lift.
Need a joint that is not listed? Send the torque, speed, size and interface you need. Maglev comes back with a sourced or custom option and one price, fixed before you commit.
Request a custom joint